
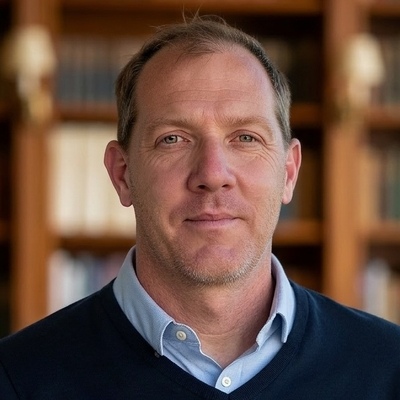
Rian Bogle
Principal Architect at Agility Robotics
Actions
Rian Bogle is Principal Architect at Agility Robotics, where he's building Kubernetes-based platforms to reliably manage fleets of humanoid robots at the edge. He's passionate about making distributed systems work in environments that are anything but predictable — where the "nodes" walk, fall, and get back up. Outside of work, he geeks out on cloud networking, robot identity, and whatever edge case the robots throw at him next.
Look Before You Leap: Preventing In-Motion K8s Updates in Fleet Robotics
Deploying Kubernetes onto mobile hardware like humanoid robots introduces severe physical risks. While GitOps tools can use "Sync Windows", applying an automated update or restarting a container while a heavy robot is moving can have real-world consequences.
To achieve true defense-in-depth, we implemented a custom Kubernetes Admission Controller directly on the edge cluster. Acting as an infrastructure-level gatekeeper, it intercepts all API requests and evaluates them against the robot's state. Regardless of GitOps schedules, modifications are safely blocked if the hardware is in a high-risk state.
This session explores a production architecture designed to bridge the gap between cloud-native infrastructure and live hardware We will detail how the admission webhook interfaces directly with the active robot, how it catches risks missed by static schedules, and the essential considerations of "break-glass" overrides to prevent lockout during edge cases
Please note that Sessionize is not responsible for the accuracy or validity of the data provided by speakers. If you suspect this profile to be fake or spam, please let us know.
Jump to top