
Session
What Self-Driving Cars Taught Me About Reliable AI Agents
Before I built agents, I built real-time perception for autonomous vehicles. A robot does not pause to think. It ingests LiDAR and camera data, runs inference under a deadline, and degrades safely when a sensor drops or a model returns noise. Agents fail the same ways, and most teams rediscover the lessons one outage at a time.
This talk maps reliability engineering from robotics onto agent systems. Deadline budgets and timeouts, so one slow tool does not stall the run. Health checks and fallbacks, the agent version of a dropped sensor. Tracing on every step, so a failure becomes reproducible instead of a mystery. Partial results over crashes, and human checkpoints placed where a wrong action gets expensive.
Every example comes from systems I built and debugged myself, both robot pipelines and agent workflows, including the ones I got wrong first. You leave with a reliability checklist drawn from a field where failure costs more than a bad demo.
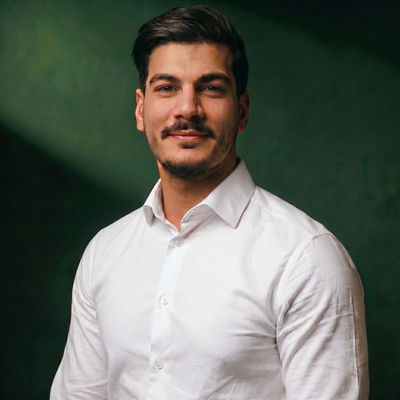
Hussein Loubani
AI Engineer at CIAD | International Speaker on AI Agents and Computer Vision
Montbéliard, France
Links
Please note that Sessionize is not responsible for the accuracy or validity of the data provided by speakers. If you suspect this profile to be fake or spam, please let us know.
Jump to top